Naif's research interests span control theory, autonomous systems, and robotics. He is particularly interested in nonlinear, robust, adaptive, and distributed control, with an emphasis on developing control methods for dynamical systems subject to uncertainty, disturbances, limited information, and interactions among multiple agents. His previous work includes modeling and control of aerial robotic systems, multi-agent coordination, and simulation of autonomous systems.
Biography
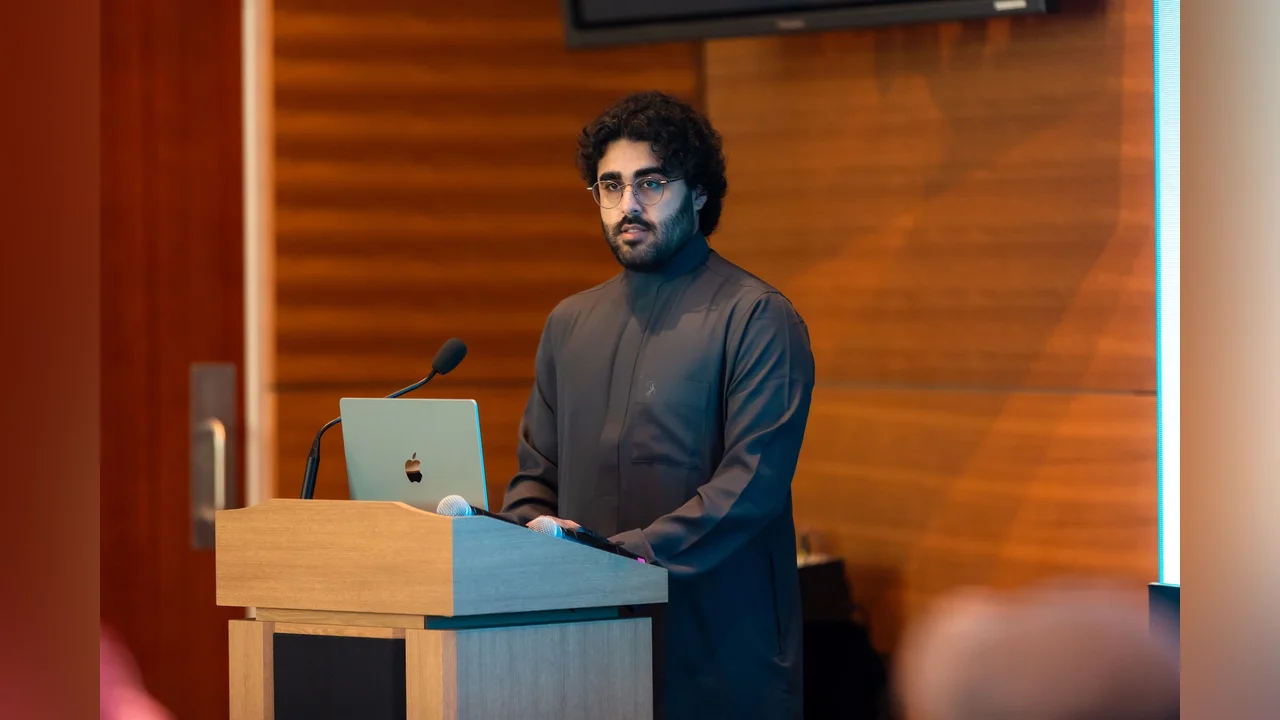
Naif is a PhD student in Electrical and Computer Engineering at King Abdullah University of Science and Technology (KAUST), working under the supervision of Prof. Alessandro Astolfi in the area of systems and control.
His research interests center on nonlinear, robust, adaptive, and distributed control, particularly for autonomous, robotic, and networked dynamical systems operating under uncertainty, disturbances, and communication constraints.
Naif's background spans electrical engineering, robotics, autonomous systems, mathematical modeling, simulation, and experimental implementation. He has worked with classical and modern control methods including PID control, state-space methods, LQR, stability analysis, and multi-agent control. His technical experience also includes MATLAB/Simulink, Python, ROS 2, and Gazebo.
He is particularly interested in research that connects rigorous control-theoretic results with realistic physical systems, including autonomous vehicles, robotic platforms, and interconnected agents. His broader research goal is to develop control methodologies that remain reliable when models are uncertain, environments change, disturbances are present, or information is distributed across multiple systems.
Expertise and Interests
Naif is a control systems researcher interested in developing rigorous control methods for physically meaningful applications. His work focuses on the analysis and control of autonomous, robotic, and networked dynamical systems, particularly in the presence of uncertainty, disturbances, and communication constraints.
Qualifications
Education
- Master of Science (M.S.)
- Robotics and Autonomous Intelligent Systems, King Fahd University of Petroleum and Minerals, Saudi Arabia, 2026
- Bachelor of Science (B.S.)
- Electrical Engineering, Prince Mohammad bin Fahd University, Saudi Arabia, 2023
- Arabic
- Native or bilingual proficiency
- English
- Native or bilingual proficiency
- Urdu
- Professional working proficiency
Languages
Patents
“Wireless Sensor Network Smart Parking System” (US 12,488,711 B1). The invention focuses on using a wireless sensor network to detect parking-space occupancy and support more efficient parking monitoring and management through distributed sensing and communication.
Projects
Crazyflie-based multi-UAV project focused on swarm coordination, formation control, and autonomous flight. The project involved developing and testing control and communication workflows for multiple Crazyflie drones, with simulation and integration work using ROS 2 and Gazebo as a foundation for coordinated multi-agent demonstrations and future hardware-in-the-loop testing.